FREE · PDF
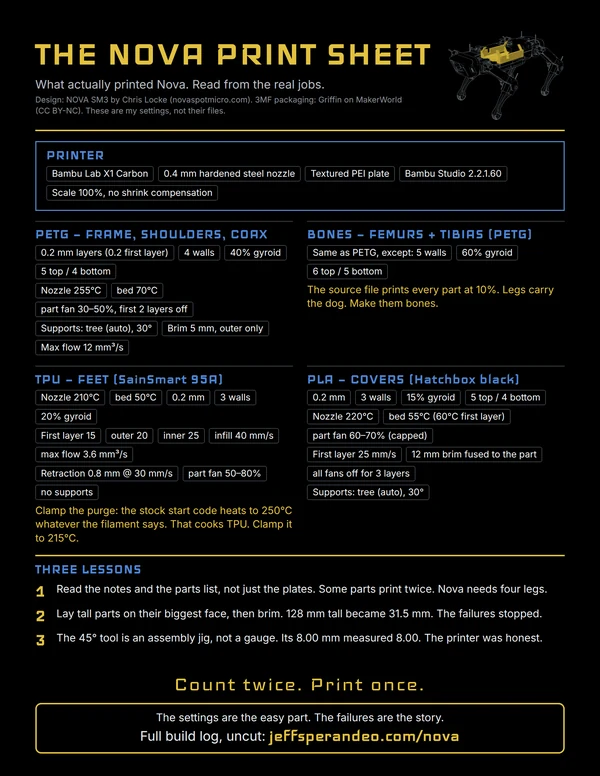
THE NOVA PRINT SHEET
The real settings that printed Nova, and the three mistakes that cost me.
One email with the guide. No spam, no list.
 ASK TOBY
Nova. A four-legged robot, printed and built from zero.
Design: NOVA SM3 by Chris Locke (novaspotmicro.com). 3MF packaging: Griffin on MakerWorld (CC BY-NC).
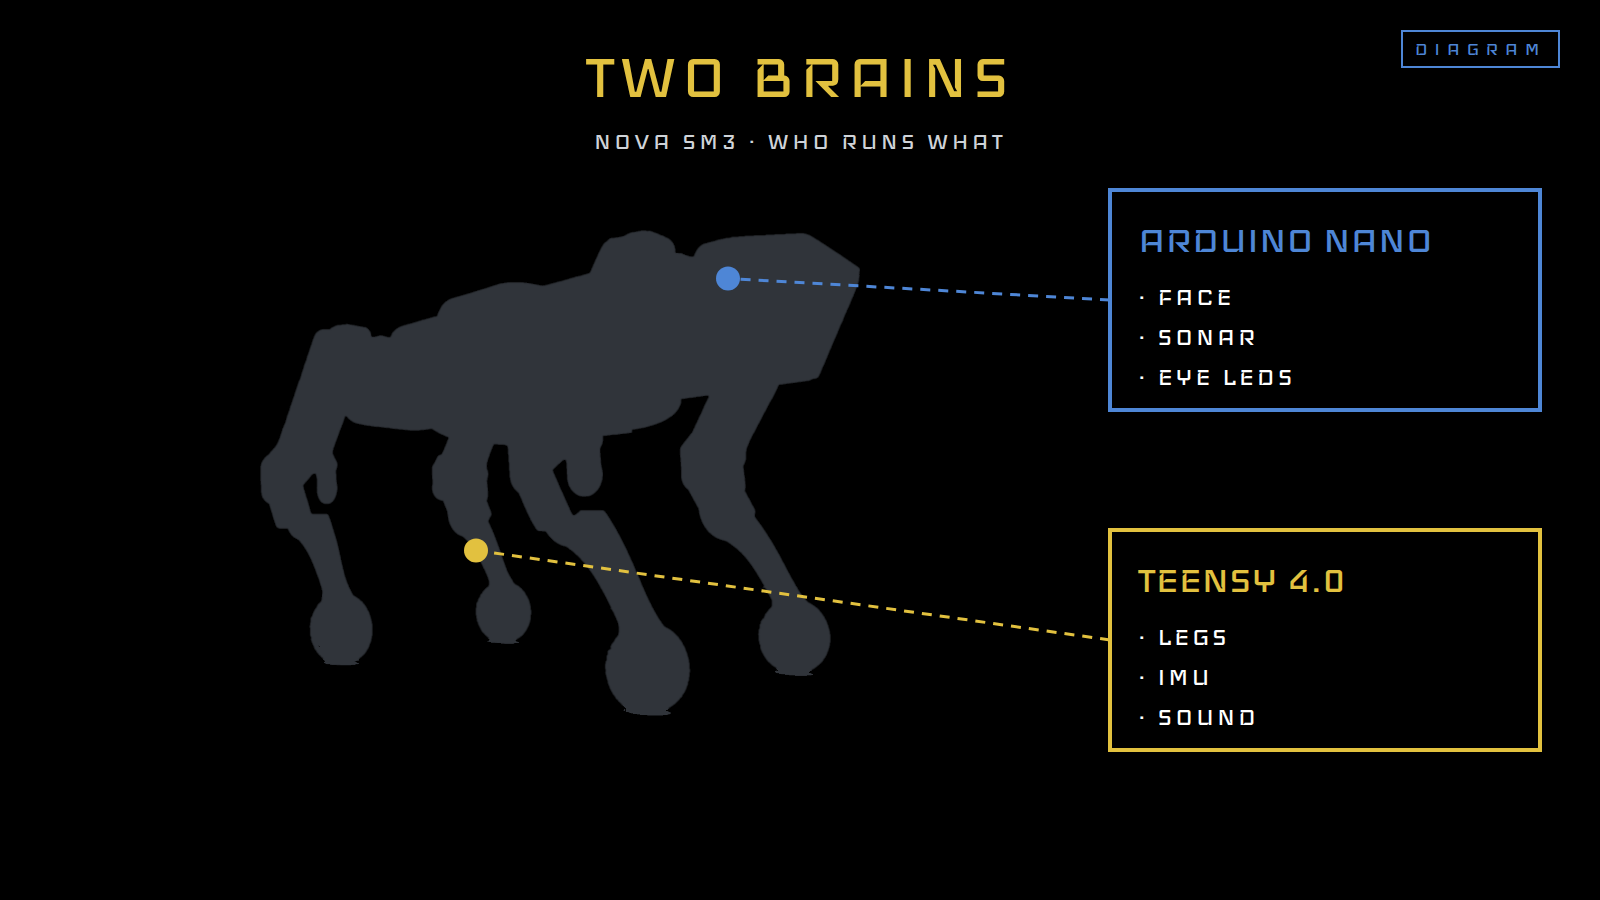
Nova is a four-legged robot I'm building from zero on my own bench. Printed bones, twelve servos, two brains. Every part here is real, and so is every failure.
The real settings that printed Nova, and the three mistakes that cost me.
One email with the guide. No spam, no list.
Mid-build: legs calibrating, body going together, first power-on still ahead.
Sort the parts (done)
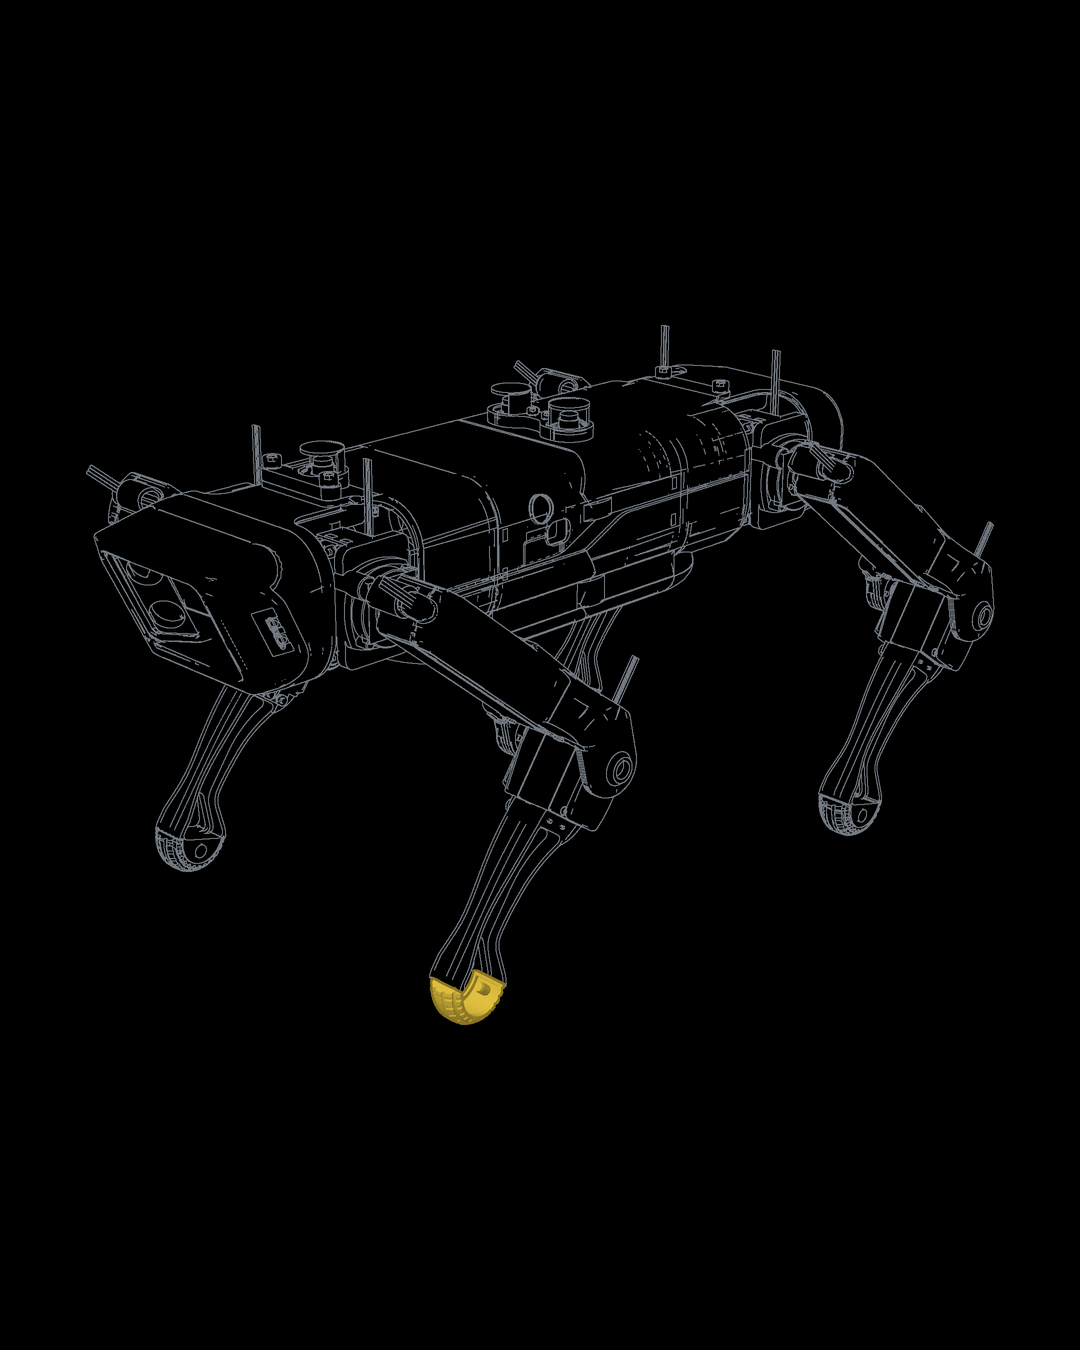
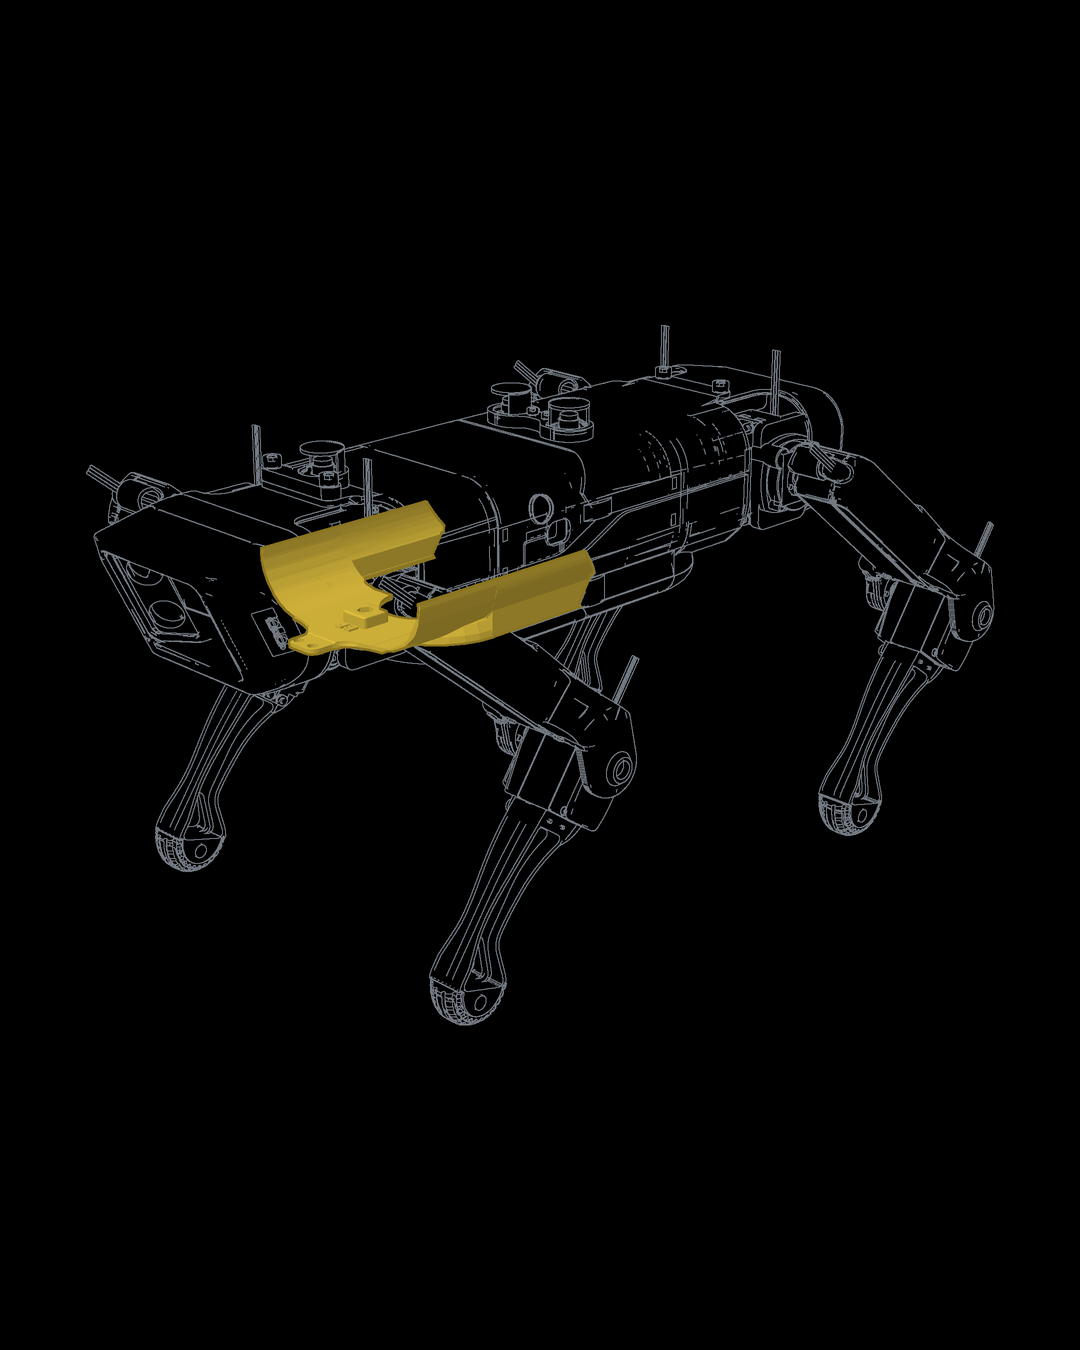
Lay out covers, frame and feet before building.
Bench-test the electronics (done)
Prove every module works first.
Calibrate all twelve servos (in progress)
The stage that protects everything after it.
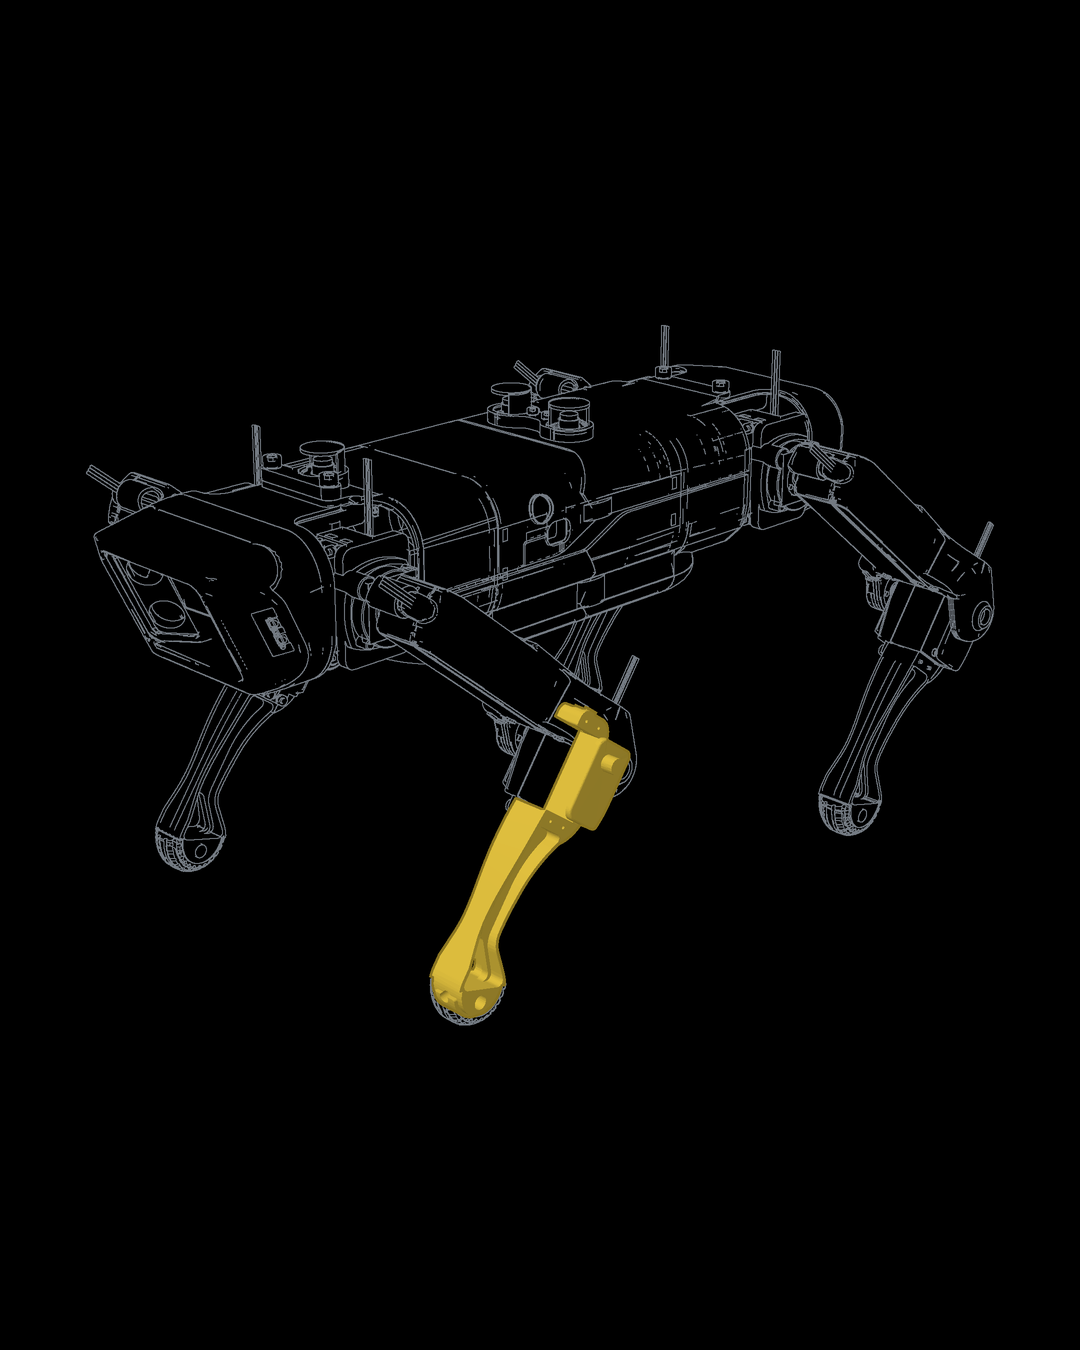
Build the legs (in progress)
Four identical legs, three joints each.
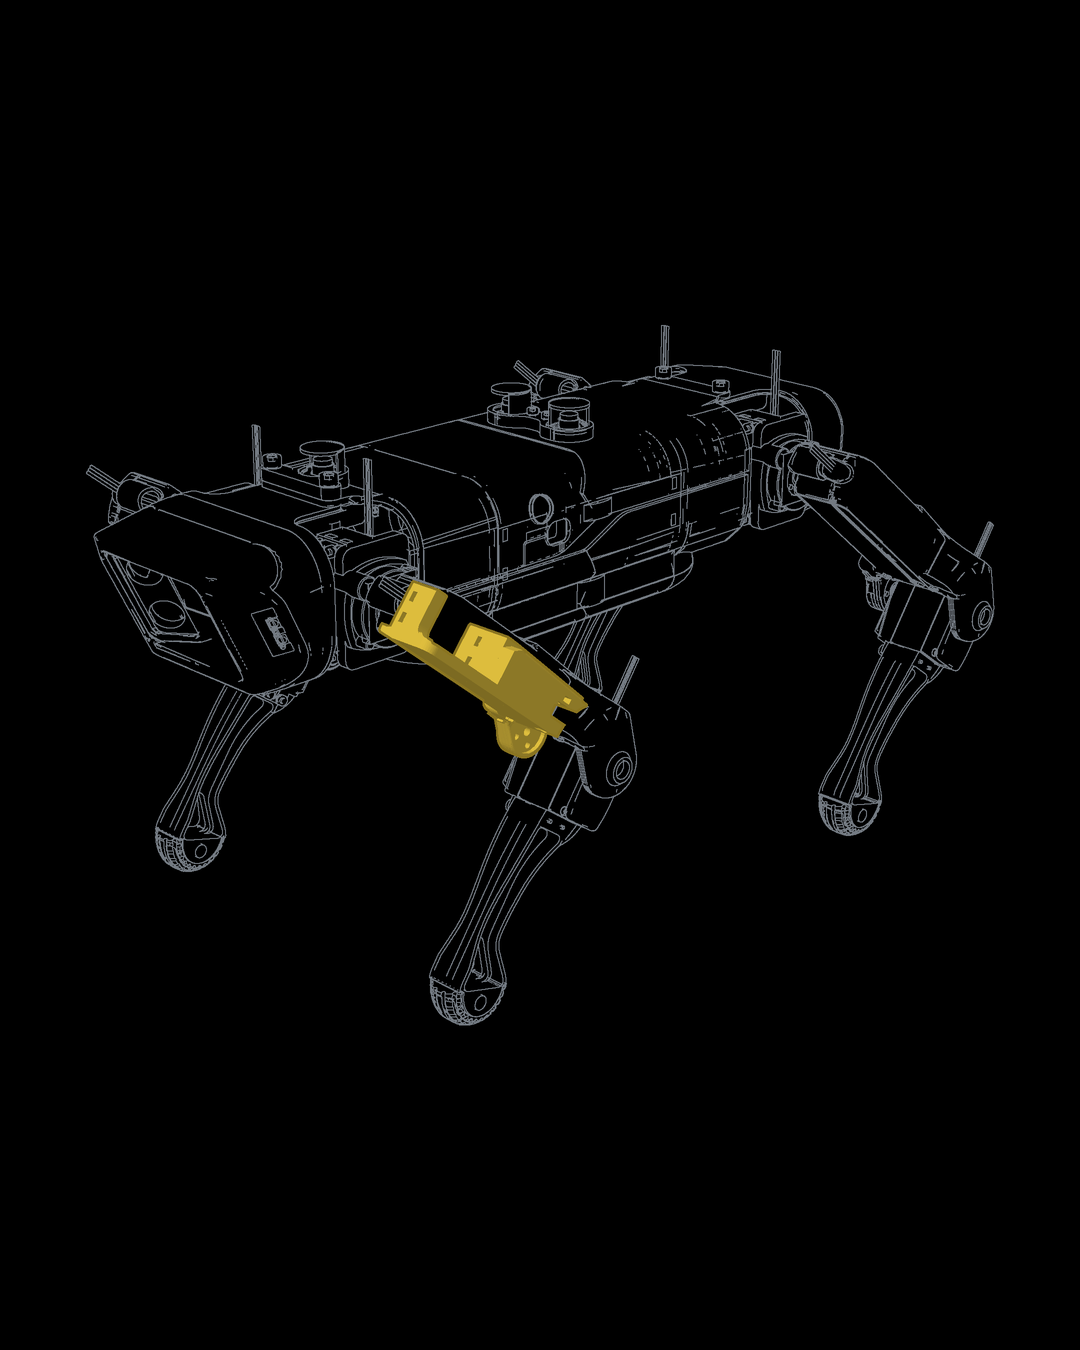
Build the body (in progress)
Chassis trunk plus shoulder stacks.
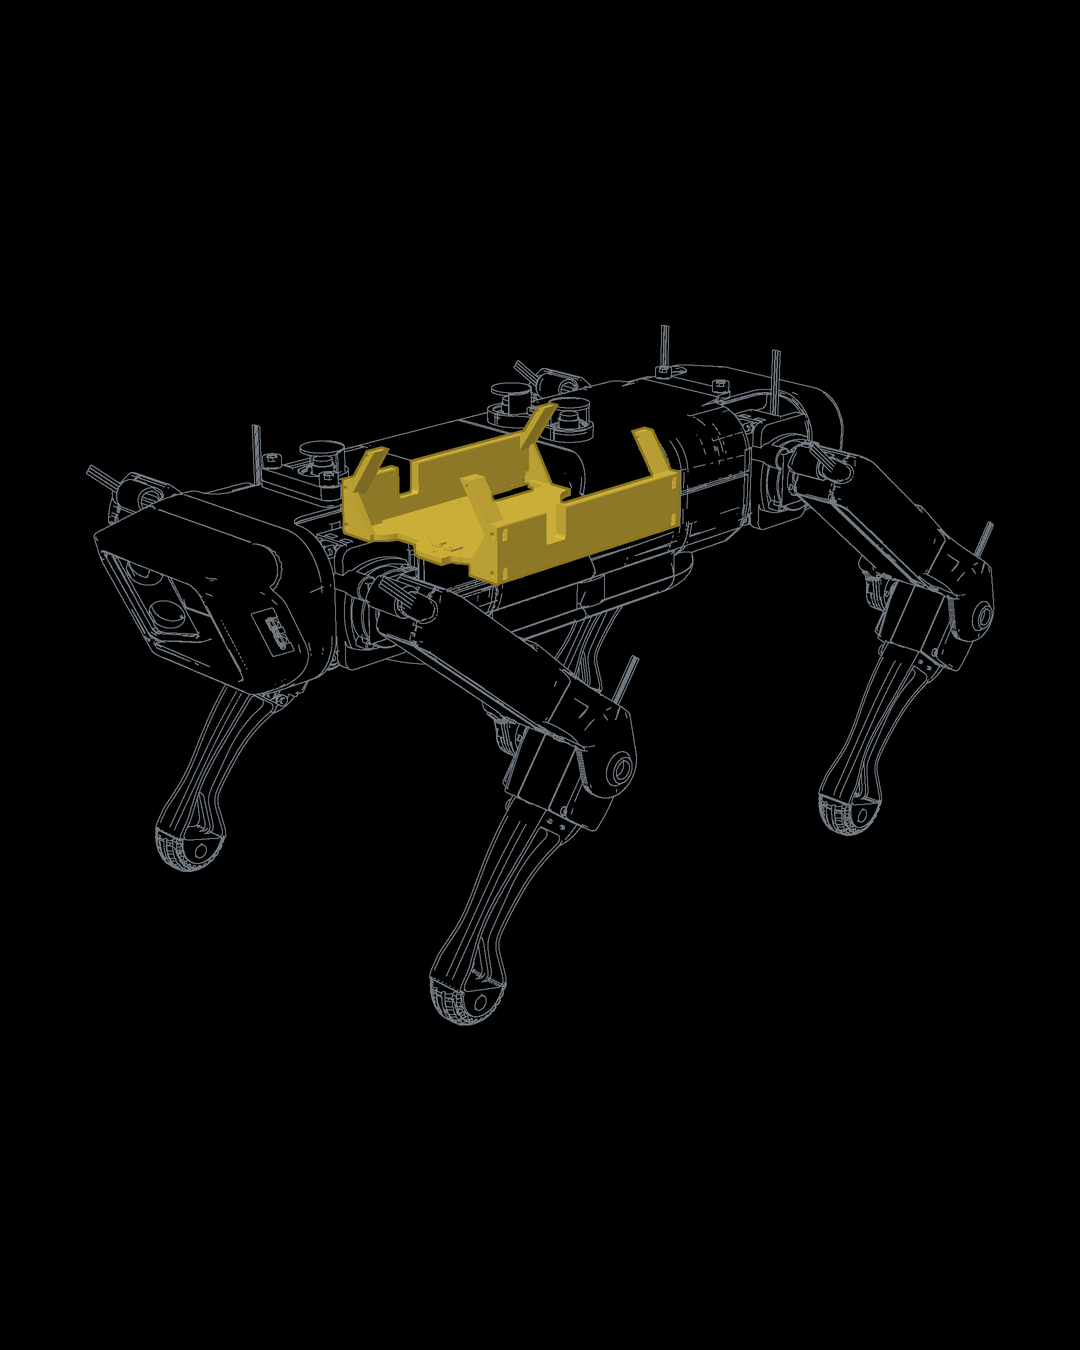
Mount the electronics (in progress)
Everything except the legs lives in the chassis.
Wire it up (not started)
Power first, then signals.
Load the firmware (not started)
Two boards, two programs.
First power-on (not started)
The careful bit.
Covers on (not started)
Last, once she stands and walks.
BEFORE YOU GO
The real settings that printed Nova, and the three mistakes that cost me.
One email with the guide. No spam, no list.
ALL-ACCESS
Every build log, uncut footage, my own files, and every new project, for one monthly price.
FOUNDING PRICE COMING SOON
JOIN THE WAITLIST